Solids
This section covers the basic primitives of CSG geometry.
Box
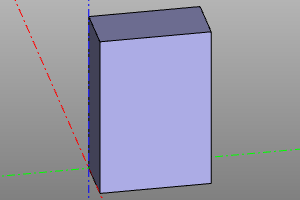
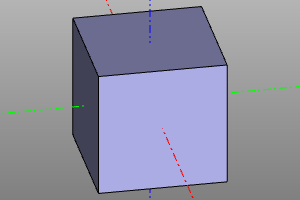
A box is defined by three dimensions: x, y and z. A single dimension a creates a cube (a, a, a). center=True places the center of the box at the origin. A string selects the axes to center along: box(10, 20, 30, center="xy") spans −5 to 5 in X, −10 to 10 in Y, and 0 to 30 in Z.
Signatures:
box(x, y, z, center=False)
box(size=(x,y,z), center=False)
box(size=a, center=False)
Examples:
box(10, 20, 30, center=False)
box(size=(10,20,30), center=False) # alternate
box(10, center=True)
Sphere
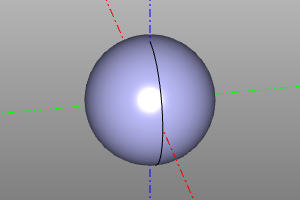
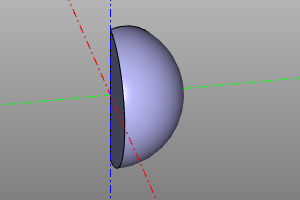
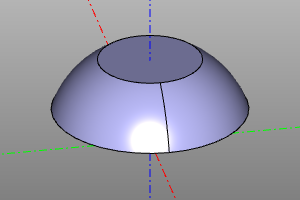
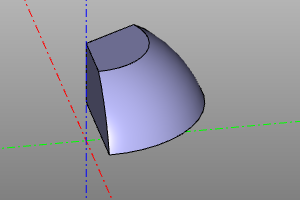
A sphere is defined by its radius. The optional yaw and pitch parameters create spherical sectors.
Signature:
sphere(r=radius, yaw=yaw, pitch=(minPitch, maxPitch))
Examples:
sphere(10)
sphere(10, yaw=math.pi*2/3)
sphere(10, pitch=(deg(20), deg(60)))
sphere(10, yaw=deg(120), pitch=(deg(20), deg(60)))
Cylinder
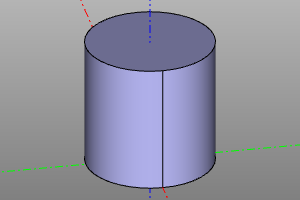
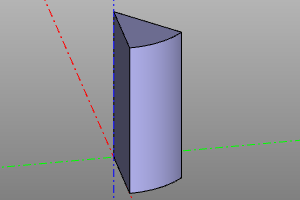
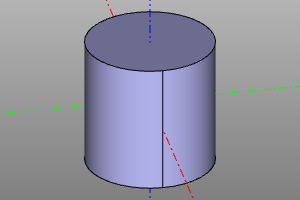
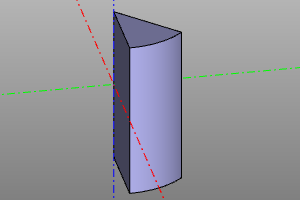
A cylinder is defined by its radius and height. The optional yaw parameter creates a cylindrical sector. With center=True, the midpoint of its height lies at Z=0.
Signature:
cylinder(r=radius, h=height, yaw=yaw, center=False)
cylinder(r=10, h=20)
cylinder(r=10, h=20, yaw=deg(45))
cylinder(r=10, h=20, center=True)
cylinder(r=10, h=20, yaw=deg(45), center=True)
Cone
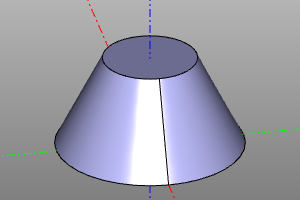
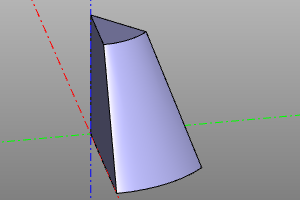
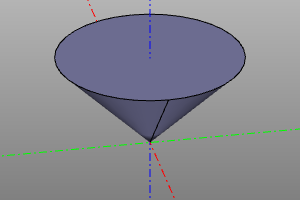
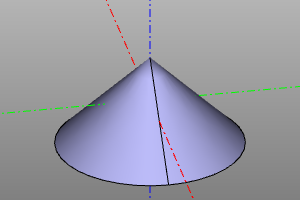
A cone is defined by its lower radius r1, upper radius r2 and height. The optional yaw parameter creates a conical sector. With center=True, the midpoint of its height lies at Z=0. Either radius may be zero to create a pointed cone.
Signature:
cone(r1=botRadius, r2=topRadius, h=height, yaw=yaw, center=False)
Examples:
cone(r1=20, r2=10, h=20)
cone(r1=20, r2=10, h=20, yaw=deg(45))
cone(r1=0, r2=20, h=20)
cone(r1=20, r2=0, h=20, center=True)
Torus
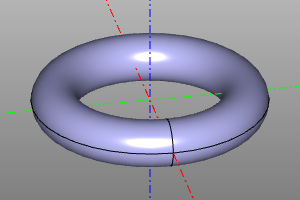
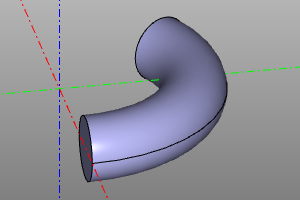
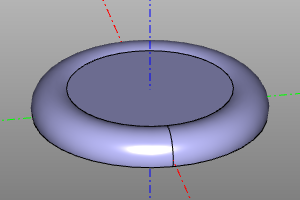
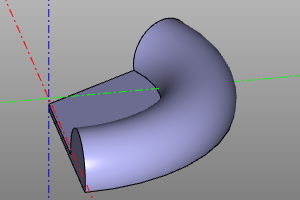
A torus is defined by its major radius r1 and minor radius r2. The optional yaw and pitch parameters create toroidal sectors.
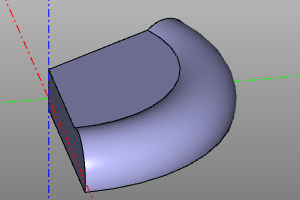
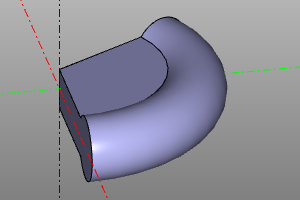
If the pitch interval excludes the inner portion, a cylindrical insert fills the corresponding region in the center. If it excludes the outer portion, that part of the torus is bounded by a plane.
Signature:
torus(r1=centralRadius, r2=localRadius, yaw=yaw, pitch=(minPitch, maxPitch))
Examples:
torus(r1=20, r2=5)
torus(r1=20, r2=5, yaw=deg(120))
torus(r1=20, r2=5, pitch=(deg(-20), deg(120)))
torus(r1=20, r2=5, pitch=(deg(-20), deg(120)), yaw=deg(120))
torus(r1=20, r2=5, pitch=(deg(-140), deg(140)), yaw=deg(120))
torus(r1=20, r2=5, pitch=(deg(-20), deg(190)), yaw=deg(120))
Half-space
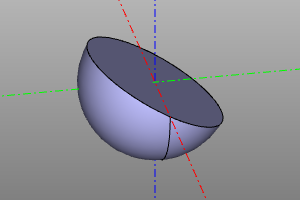
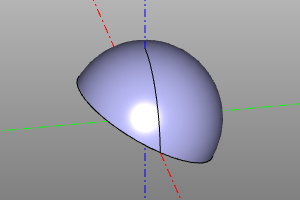
A special solid representing the lower half-space. Like other solids, it supports transformations and can be positioned to represent any half-space. It cannot be displayed directly. Use it with difference and intersection operations.
sphere(r=10) - halfspace().rotateX(deg(150))
sphere(r=10) ^ halfspace().rotateX(deg(150))
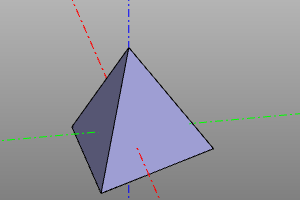
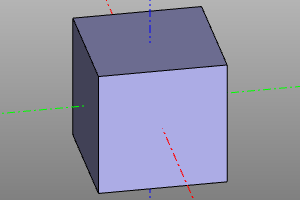
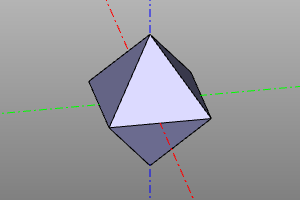
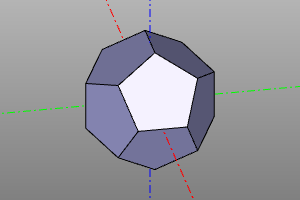
Platonic solids
Constructing Platonic solids. The implementation is based on https://github.com/qalle2/plato.scad
| Regular polyhedron | Vertices | Edges | Faces | Sides per face | Edges per vertex | Symmetry group |
|---|---|---|---|---|---|---|
| Tetrahedron | 4 | 6 | 4 | 3 | 3 | Td |
| Hexahedron | 8 | 12 | 6 | 4 | 3 | Oh |
| Octahedron | 6 | 12 | 8 | 3 | 4 | Oh |
| Dodecahedron | 20 | 30 | 12 | 5 | 3 | Ih |
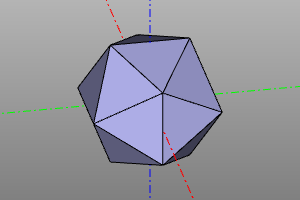
| Icosahedron | 12 | 30 | 20 | 3 | 5 | Ih |
Set the size using the circumscribed radius r or the edge length a.
Signatures:
zencad.tetrahedron(r=1, a=None, shell=False)
zencad.hexahedron(r=1, a=None, shell=False)
zencad.octahedron(r=1, a=None, shell=False)
zencad.dodecahedron(r=1, a=None, shell=False)
zencad.icosahedron(r=1, a=None, shell=False)

# Alternative syntax
zencad.platonic(nfaces, r=1, a=None, shell=False)
Example:
# By radius:
tetrahedron(10)
hexahedron(10)
octahedron(r=10)
dodecahedron(r=10)
icosahedron(10)

# By edge length:
icosahedron(a=10)

# Alternative syntax:
zencad.platonic(4, 10)
zencad.platonic(6, 10)
zencad.platonic(8, 10)
zencad.platonic(12, 10)
zencad.platonic(20, 10)